
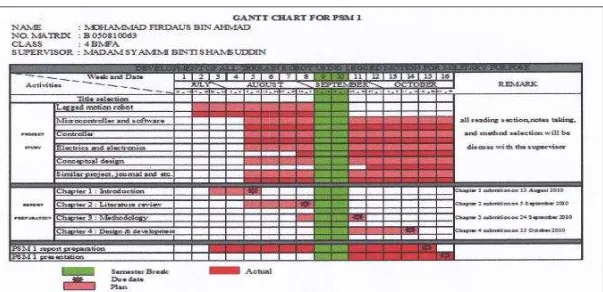
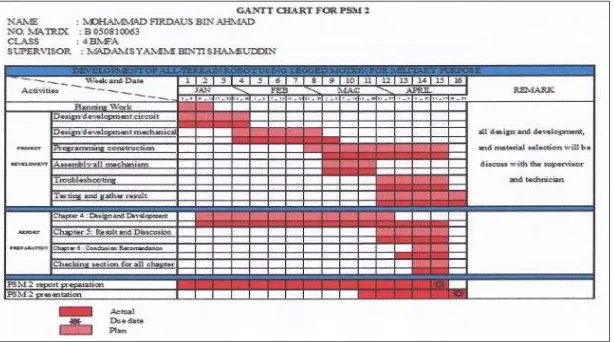
Development Of All-Terrain Robot Using Legged Motion For Military Purpose.
Teks penuh
Gambar
Dokumen terkait
This paper introduces an integrated design process for the design of the five fingered gripper suitable for dexterous motion by using simulation and experiment of prototype..
In this project, in order to make sure the electronic component and wiring for the CH3 – R robot stay protected without damaging other component and movement, the
To design and develop a PID controller for line following robot that able follows a line in high speed and accurately to reduce wobbling motion (oscillation) and be able to
Thus, it is very suitable to propose a title on development of air duct robot for HVAC system to design and construct a reliable air duct robot to perform cleaning and
It is common where a robot development process emphasizes on electronic systems and programming aspects but little on the mechanical characteristic. If the robot had good
The primary scope of this research involves the developing a stable walking motion for humanoid robot by using cubic polynomial method which refers to the
• Derive the equation of motion for slider crank, stepper motor and 7-DOF full vehicle model, 3-DOF motion platform.. • PSM1
A Neuromorphic Motion Controller for a Biped Robot Michele Folgheraiter, Amina Keldibek, Bauyrzhan Aubakir, Shyngys Salakchinov 1, Giuseppina Gini, Alessio Mauro Franchi 2 Humans
