
Adaptive Control of Space Robot Manipulators with Task Space Base on Neural Network
Teks penuh
Gambar
Dokumen terkait
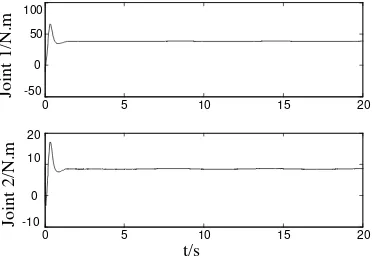
As can be seen from the figure 1,after the initial learning, neural network can get to complete learning and good approximation for parameters uncertainty model in less than 2s, it
Abstract— This paper presents synthetic checking controller for robot manipulator with flexible joints, dynamics of executive motors and affect of disturbance based on radial basic
Mohamed Elouni Adaptive PID Fault-Tolerant Tracking Controller for Takagi-Sugeno Fuzzy Systems with Actuator Faults: Application to Single-Link Flexible Joint Robot designing a
The proposed adaptive-robust tracking controller is successfully applied to a nonholonomic wheeled mobile robot and experimental results are presented to validate the effectiveness
With existing study This expected can help the development of the hexapod robot team AL-JAZARI in mission victim rescue use detection of victim objects using Pixy Camera Arduino and
A design of two-wheeled robot TWR trajectory tracking control system TTCS using model reference adaptive control method is presented.. The TTCS is to steer the TWR track a desired
Forward dynamics problem For further investigation of the operability of the system of bilateral control by the teaching method, it is necessary to construct a dynamic model of a space
